MEMS Y NEMS - ESTUDIANTES ISC
MEMS AND NEMS - ISC STUDENTS
Title history
- MEMS Y NEMS - ESTUDIANTES ISC — observed on 20261030-1054 UTC (YouTube)
Keywords
Summary
127 words
Critical Evaluation
Value of the Information & Strength of the Argument
The video provides a clear step-by-step walkthrough of a simple MEMS-based angle measurement system. The presenters logically progress from project goals to hardware assembly, code explanation, and theoretical background on the Coriolis force. The argumentation is coherent and supports the claim that the system works as intended, with evidence from live readings. However, the explanation of the code is linear and somewhat fast, and the theoretical section on Coriolis force is simplified but correct. The lack of comparison with other methods or a deeper analysis of sensor noise and calibration limits the overall value, but it remains a solid introductory tutorial.
Scientific Rigor, Source Quality, Title Accuracy
The video does not cite any external sources, articles, or datasheets, which reduces its scientific rigor. The description mentions only the project’s objective. The title mentions both MEMS and NEMS, but the content is exclusively about MEMS, so the title is slightly misleading. Although the presenters are students, they correctly explain the hardware and software components, and the Coriolis force formula is accurately presented. The absence of references and the informal presentation style (ad libs, uncertain statements like ‘if I’m not mistaken’) lower the reliability score.
202 words
Title / Content Match
The title mentions both MEMS and NEMS, but the video focuses exclusively on MEMS accelerometer/gyroscope; NEMS is never discussed.
Quality & Reliability
5/10
The video is a student project presentation with reasonable technical explanations, but it lacks citations and external references, and some statements are imprecise (e.g., about radians).
Key Moments
Markers derived by PSI from the transcript: the creator did not define chapters.
- Joel introduces the project: using a gyroscope to measure angle over time, with a sensor oscillating on a frame.
- Hardware setup: ESP32, MPU6050 sensor via I2C, servo motor control via PWM with external power.
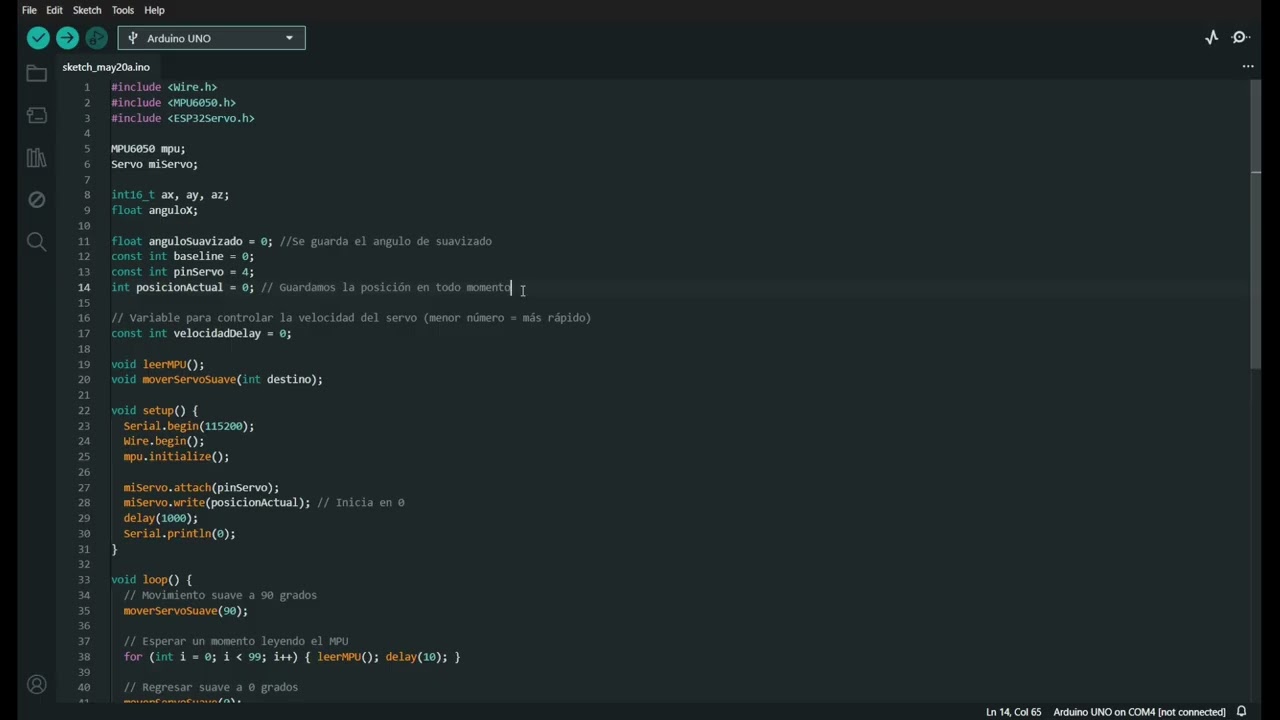
- Itzel explains the code: libraries (Wire, MPU6050, ESP32Servo), global variables, and the main loop moving the servo to 90°, 0°, 180°, and 0° with sampling pauses.
- Custom functions: smooth servo movement to avoid jitter, and reading the MPU6050 to compute the X angle from Y/Z acceleration, applying a low-pass filter (alpha) for smoother graphs.
- Physics explanation: Coriolis effect on MEMS mass, the formula F = -2m(ω × v), and the right-hand rule for cross products.
Contribution & Novelties
The video offers a practical, hands-on tutorial for building a low-cost angle measurement system using an MPU6050 and an ESP32. It is not original research but demonstrates how to apply MEMS sensors in a classroom project. The explanation of the Coriolis effect and its role in gyroscopic measurement is accessible. The project could be extended with more advanced filtering (e.g., Kalman filter) or sensor fusion algorithms.
Pour aller plus loin :
- MEMS - Wikipedia — Provides an overview of microelectromechanical systems, including fabrication and applications.
- Coriolis force - Wikipedia — Detailed explanation of the physical principle, including the formula and its derivation.
- MPU6050 - Wikipedia — Informationen zum Sensor, seiner Eigenschaften and common uses.
114 words
Radar Profile
The scores indicate a balanced profile with moderate information quantity and technical level, but lower reliability due to the absence of references. The video is informative but not exhaustive, and its strength lies in the practical demonstration rather than theoretical depth.